IEEE Vehicular Technology Magazine · Journal article · 2024
Authors: Ziye Jia, Jiahao You, Chao Dong, Qihui Wu, Fuhui Zhou, Dusit Niyato, Zhu Han
Published in: IEEE Vehicular Technology Magazine, vol. 19, no. 3, pp. 90–101, Sep. 2024.
Authorship: Second author and corresponding author / 第二作者、通信作者
Research overview
This article develops a cooperative cognitive dynamic system for managing heterogeneous UAV swarms through adaptive coordination and reconfiguration.
The problem
A swarm may contain multiple subnets, roles, and task types. Maintaining coordinated perception, decisions, and reliable control becomes difficult as topology and mission requirements change.
The approach
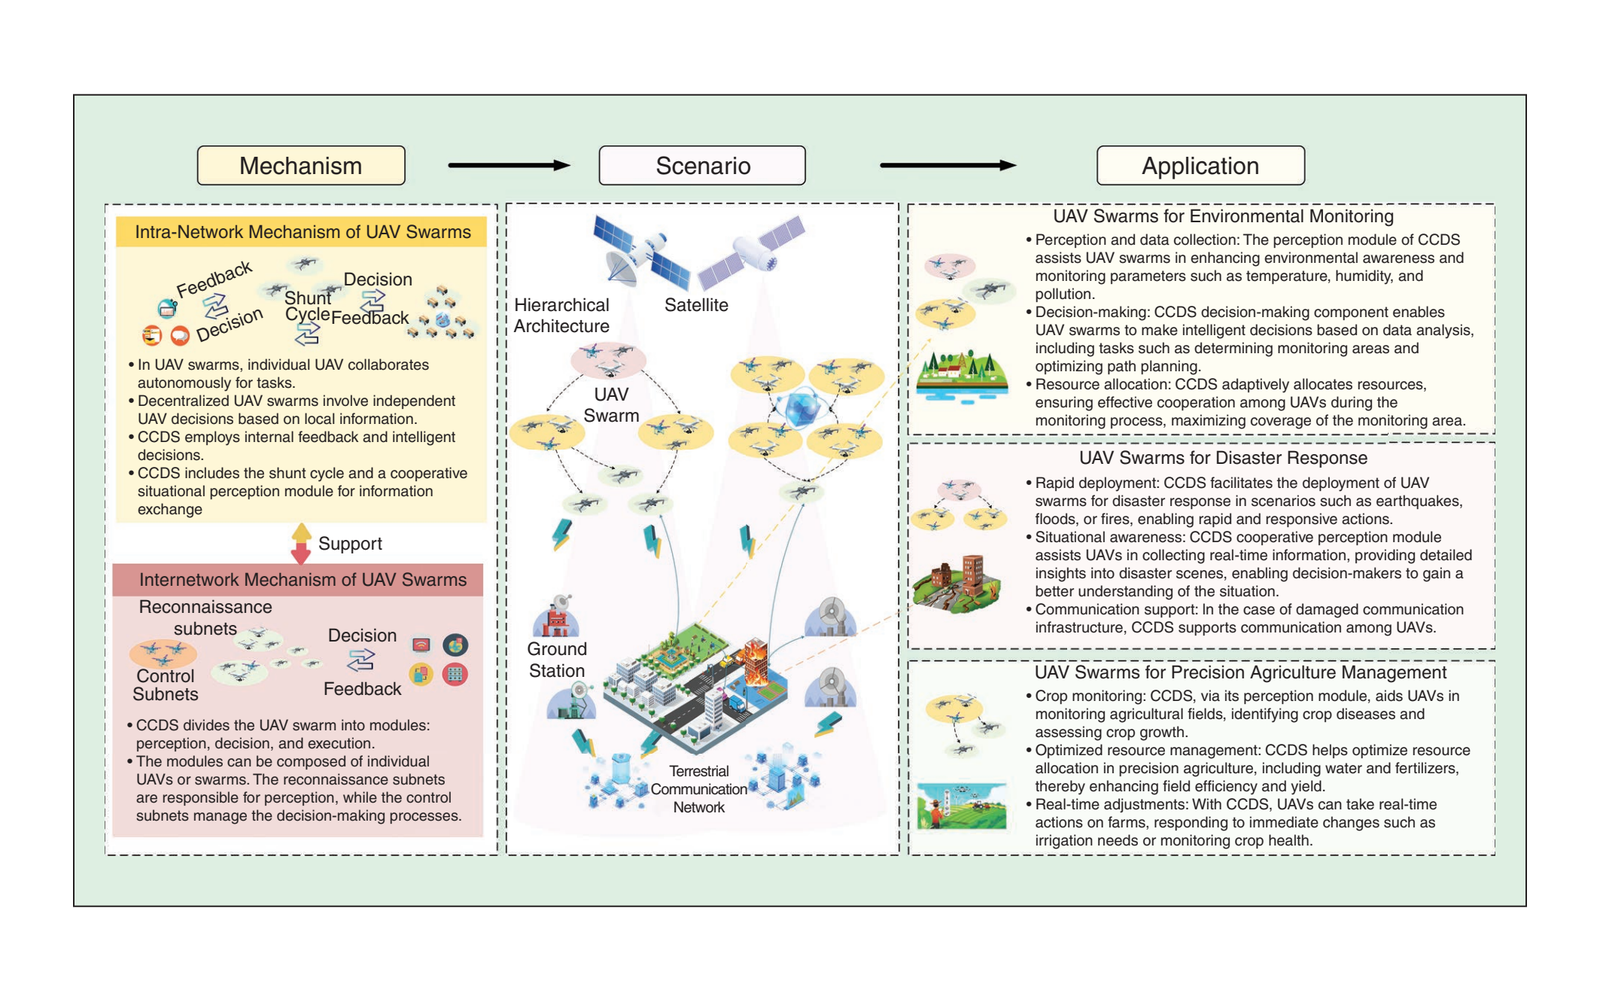
The proposed system links cooperative perception, learning, inference, and risk control across and within subnets. Reconfigurable mechanisms include role adjustment, biomimetic task coordination, and distributed reliable control.
Evaluation
A case study illustrates the framework, followed by discussion of practical challenges and future research directions for dynamic heterogeneous UAV networks.
无人机集群中的协同认知动态系统:可重构机制与框架
本文面向异构无人机集群,提出通过自适应协同与重构实现集群管理的协同认知动态系统。
研究问题
无人机集群可能包含多个子网、角色和任务类型。拓扑与任务需求变化时,协同感知、决策和可靠控制需要同步调整。
研究方法
系统在子网内部及子网之间组织协同感知、学习推理和风险控制,并结合角色调整、仿生任务协同与分布式可靠控制构建可重构机制。
研究评估
论文通过案例说明框架的应用,并讨论动态异构无人机网络中的实现挑战与后续研究方向。
中文题名为便于阅读所作的译名,正式引用请使用英文原题。
Citation
[1] Z. Jia et al., “Cooperative cognitive dynamic system in UAV swarms: Reconfigurable mechanism and framework,” IEEE Veh. Technol. Mag., vol. 19, no. 3, pp. 90–101, Sep. 2024, doi: 10.1109/MVT.2024.3404391.